About.
I build robotic systems for real-world deployment, spanning manipulation, motion planning, perception and operator tooling.
Experience
Google (via AutoRoboto)
Built robotic systems for biometric security testing on Pixel devices. Led ROS1→ROS2 migration and designed automated attack trajectory libraries.
Peanut Robotics
Owned the arm software stack on a commercially deployed mobile manipulator for hotel bathroom cleaning: trajectory generation, computer vision, and operator tooling.
Education
Carnegie Mellon University
Robotic post-processing of additive manufacturing parts at CERLAB.
Rose-Hulman Institute of Technology
Represented the USA at the E²Festa Global Capstone Design Competition in South Korea.
Currently exploring
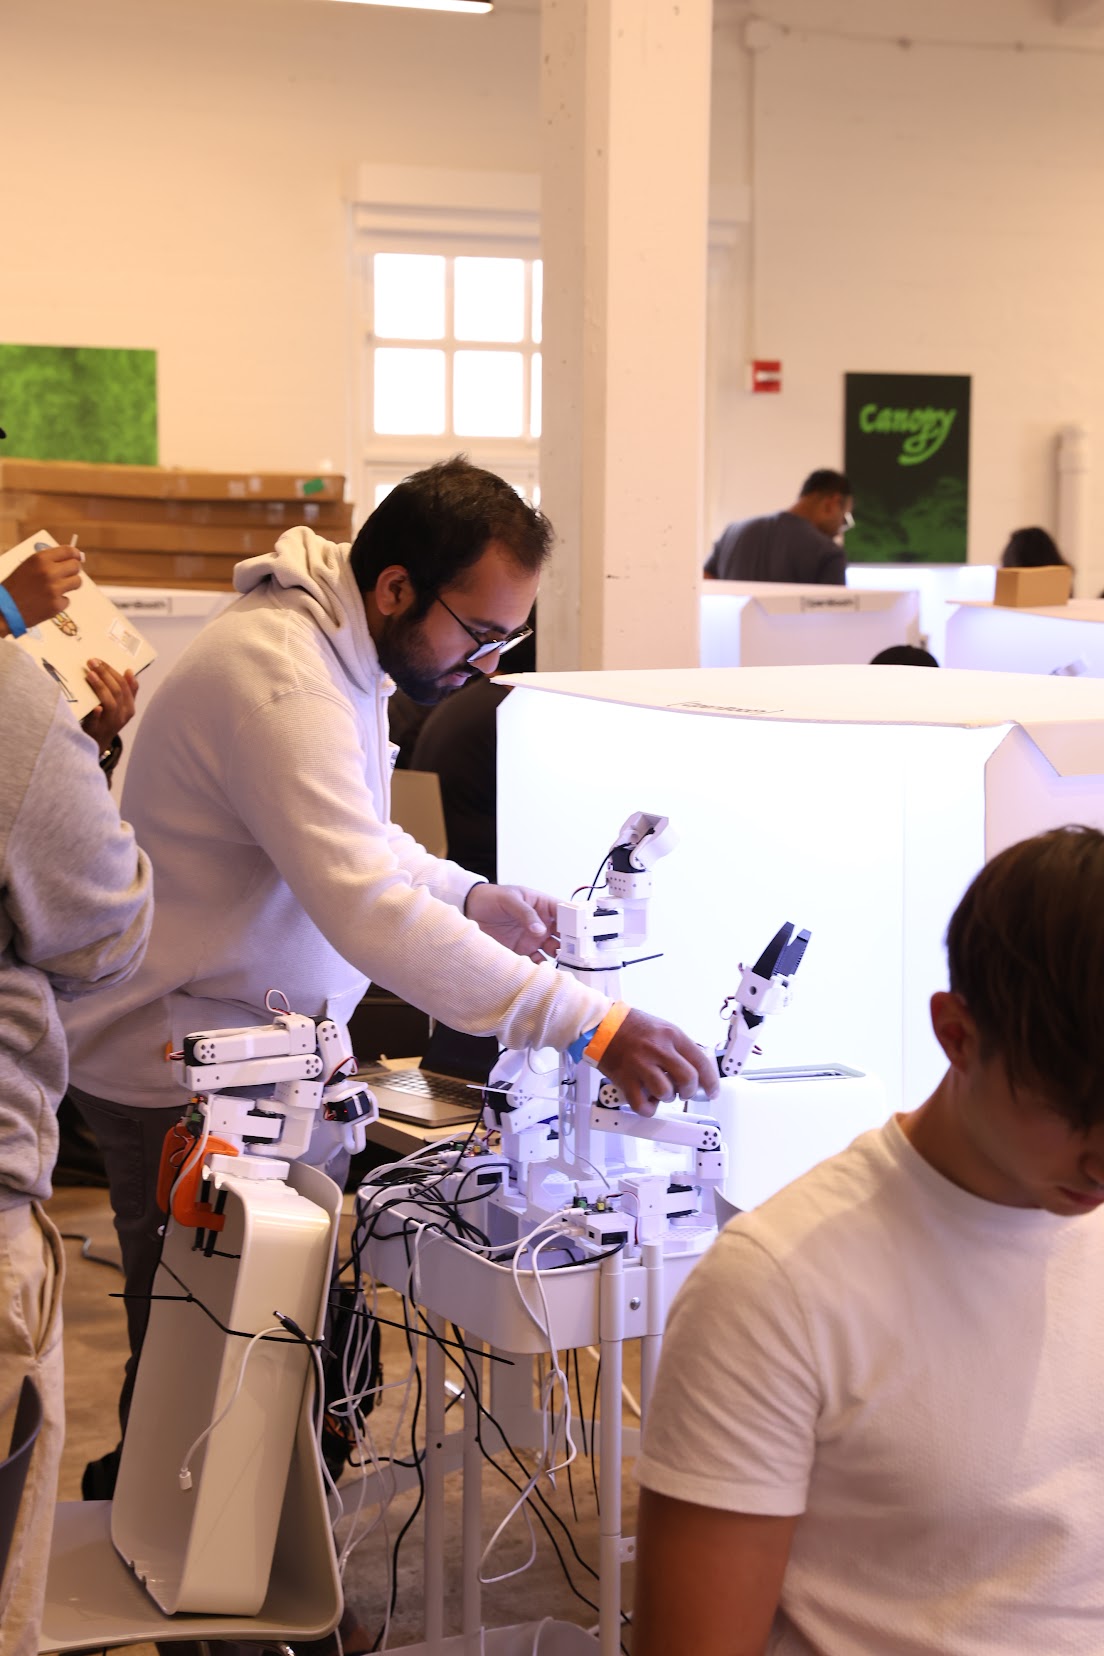
The intersection of classical robotics and learned policies: behavioral cloning, diffusion policy, foundation models. Building hands-on with the XLErobot.