Bay Area, CA · Open to robotics software and manipulation roles

I build robots. Sometimes they work.

Robotics Systems Engineer at Google (via AutoRoboto), previously Peanut Robotics. CMU grad. Outside of work, I tinker with robot arms and hands.
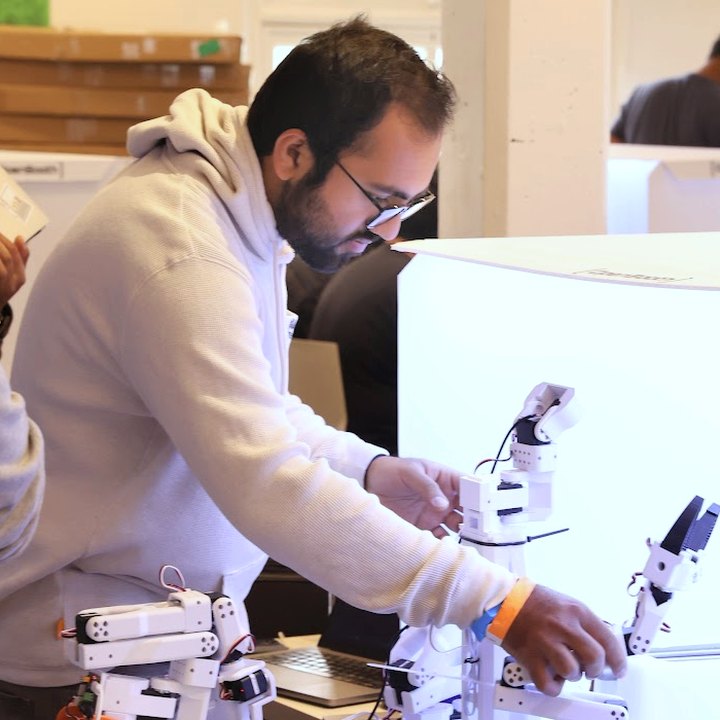
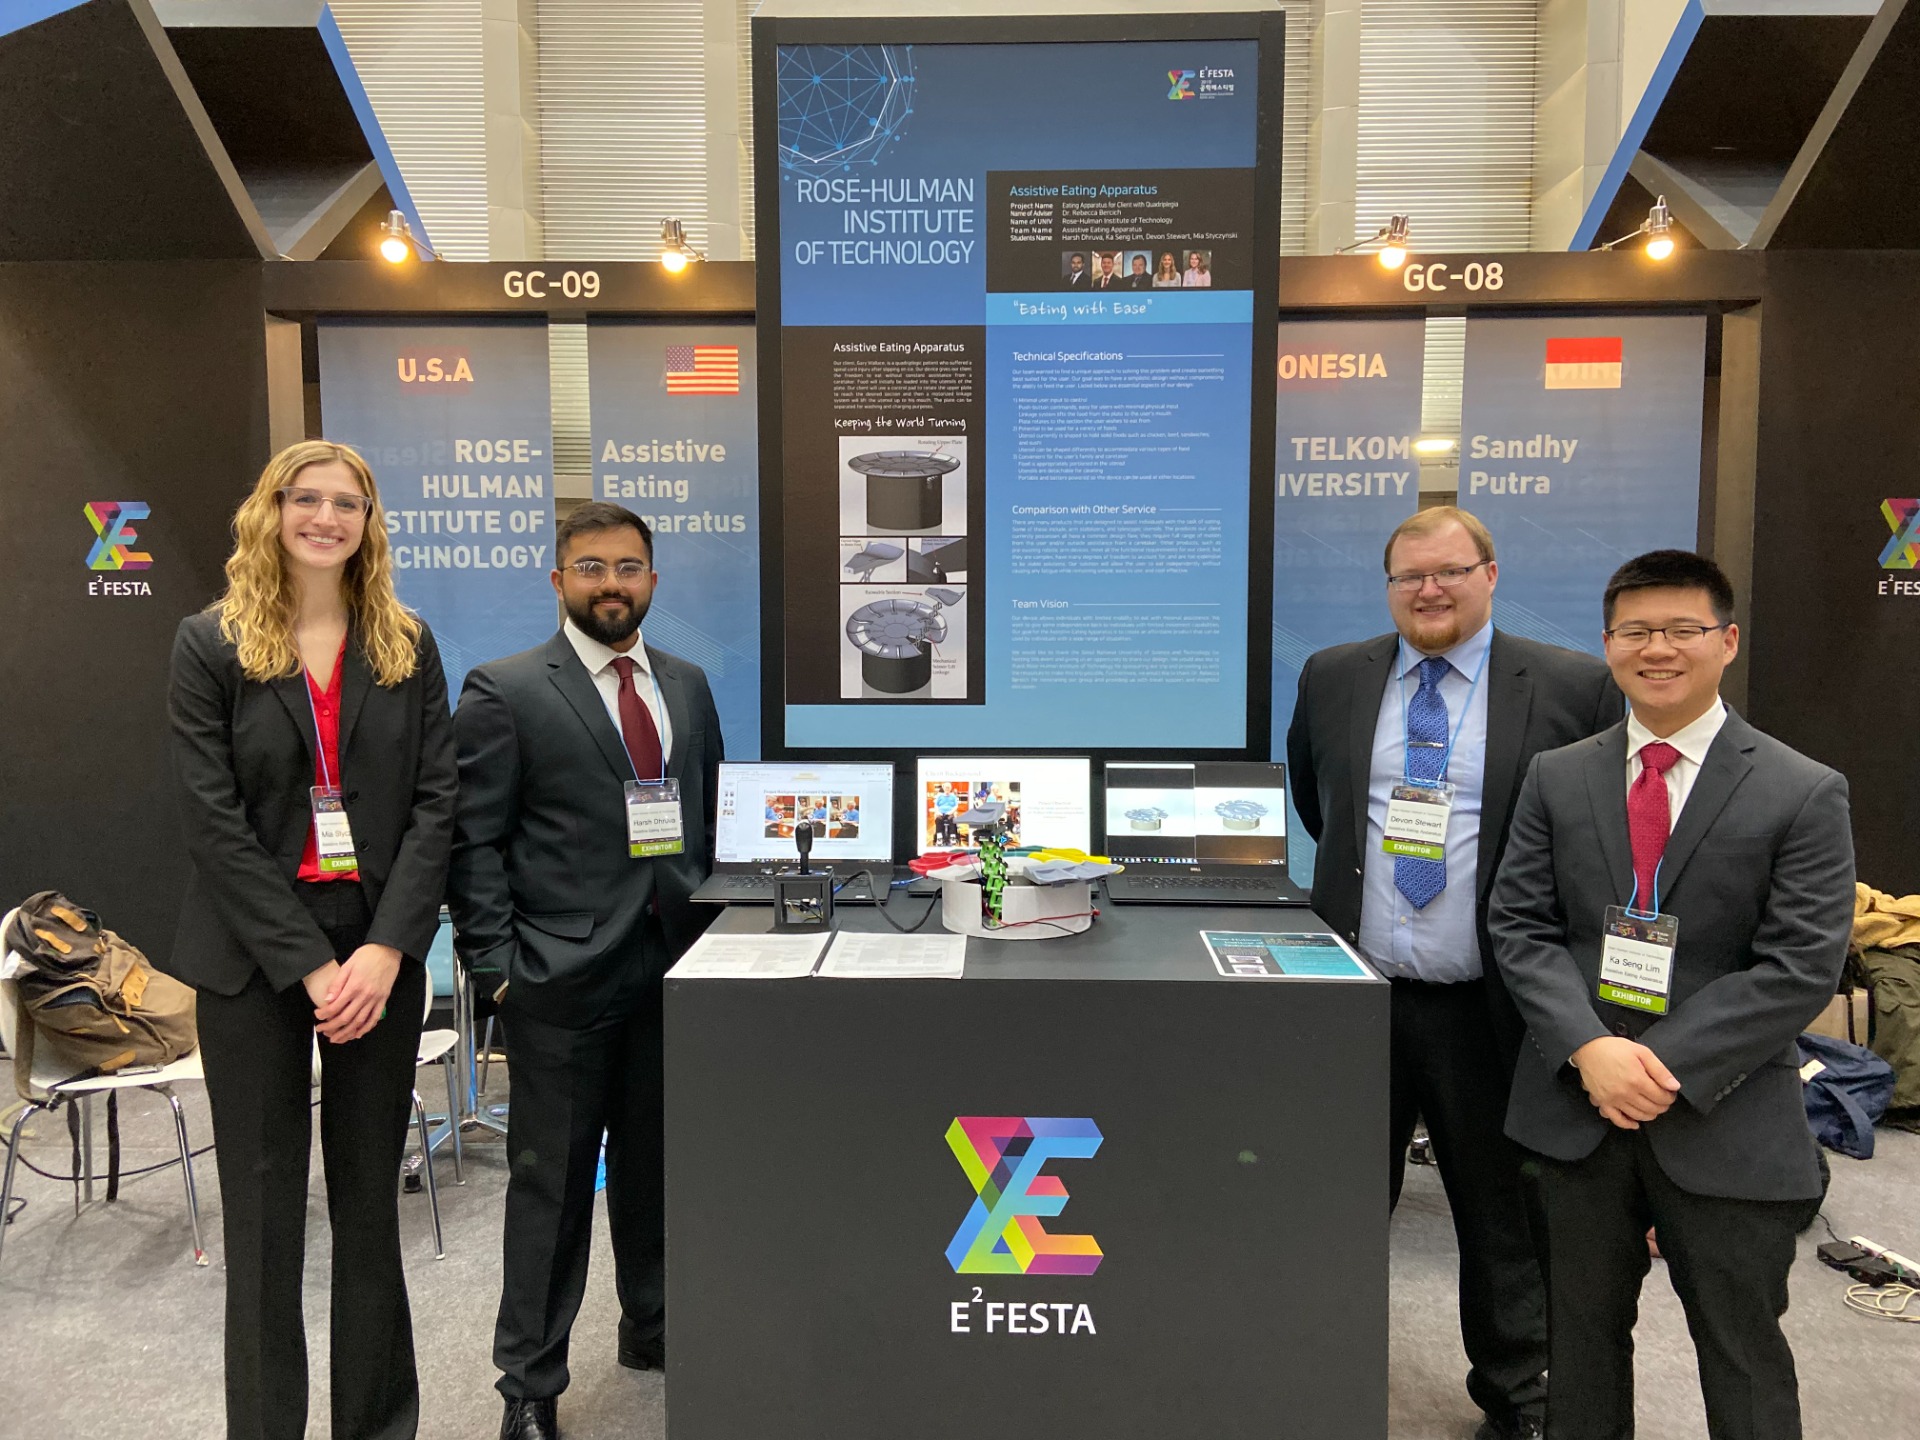
Harsh wiring up robot arms at a hackathon
hover for toast

Selected work

Highlights
Google AutoRoboto
System Integration · Google (via AutoRoboto)
Automated biometric testing for Pixel
Robotics lab automation for evaluation of Pixel biometric face authentication. Built the trajectory system and led the ROS1→ROS2 migration, deployed across 10 internal lab installations.
ROS2 xArm MoveIt System Design
Peanut Robotics
Mobile Manipulation · Jul 2022 to Apr 2024
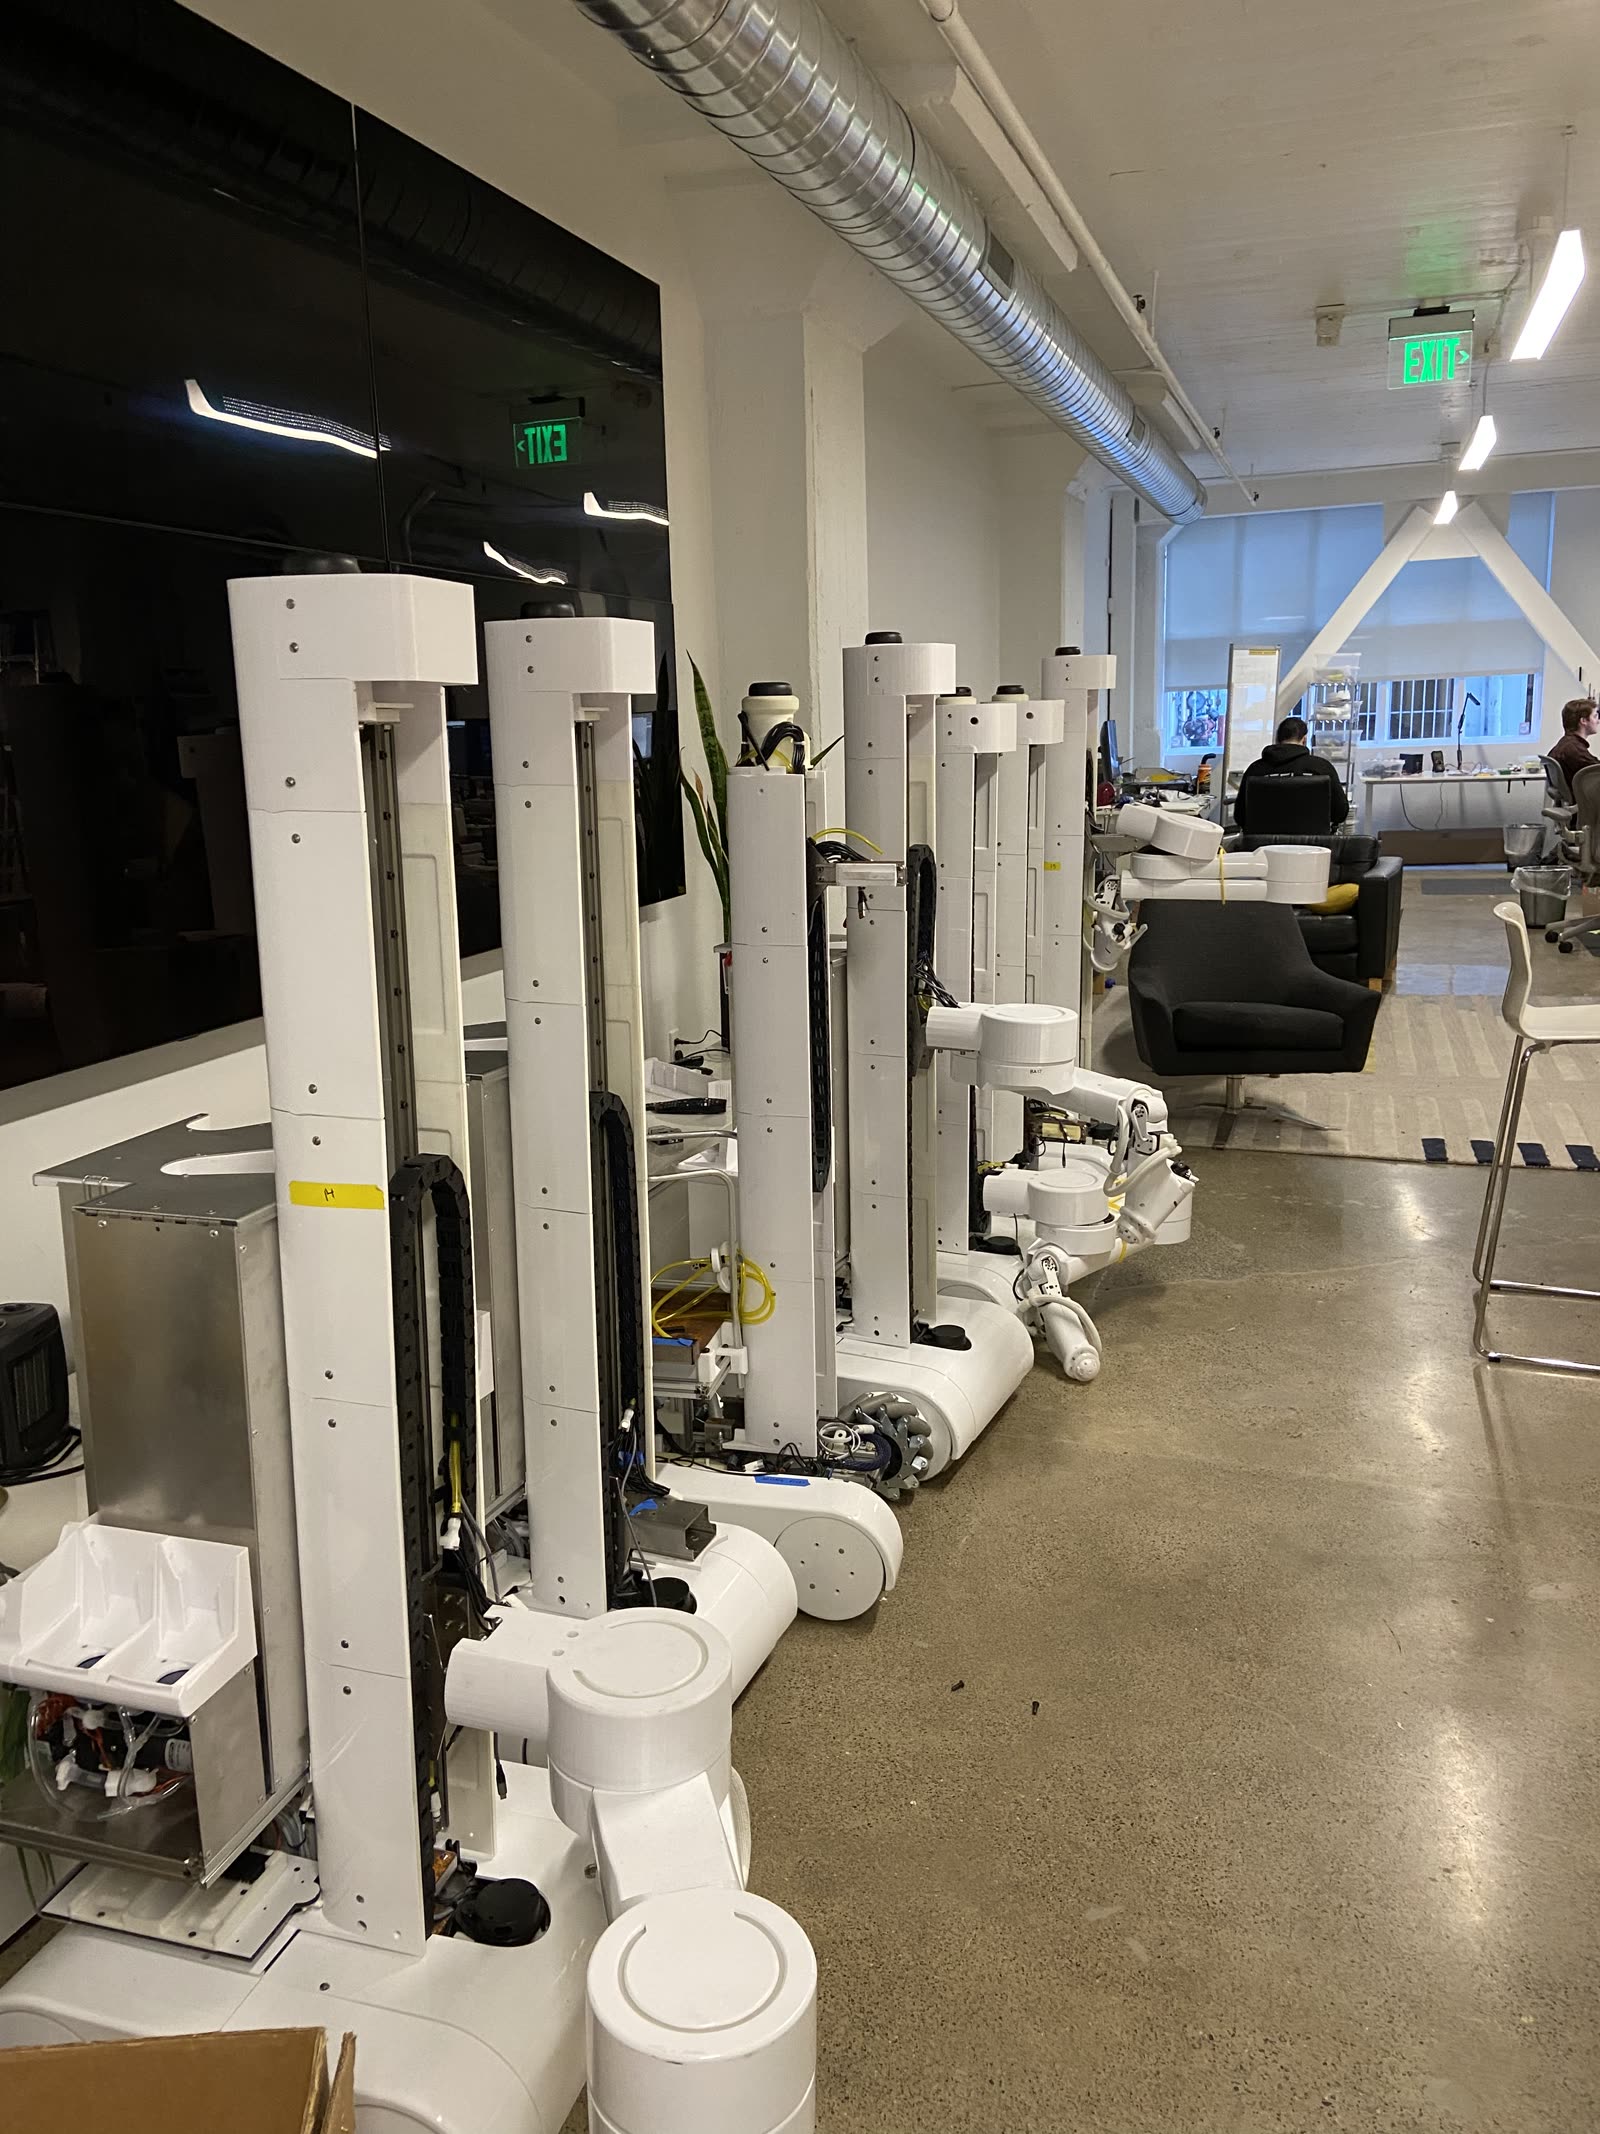
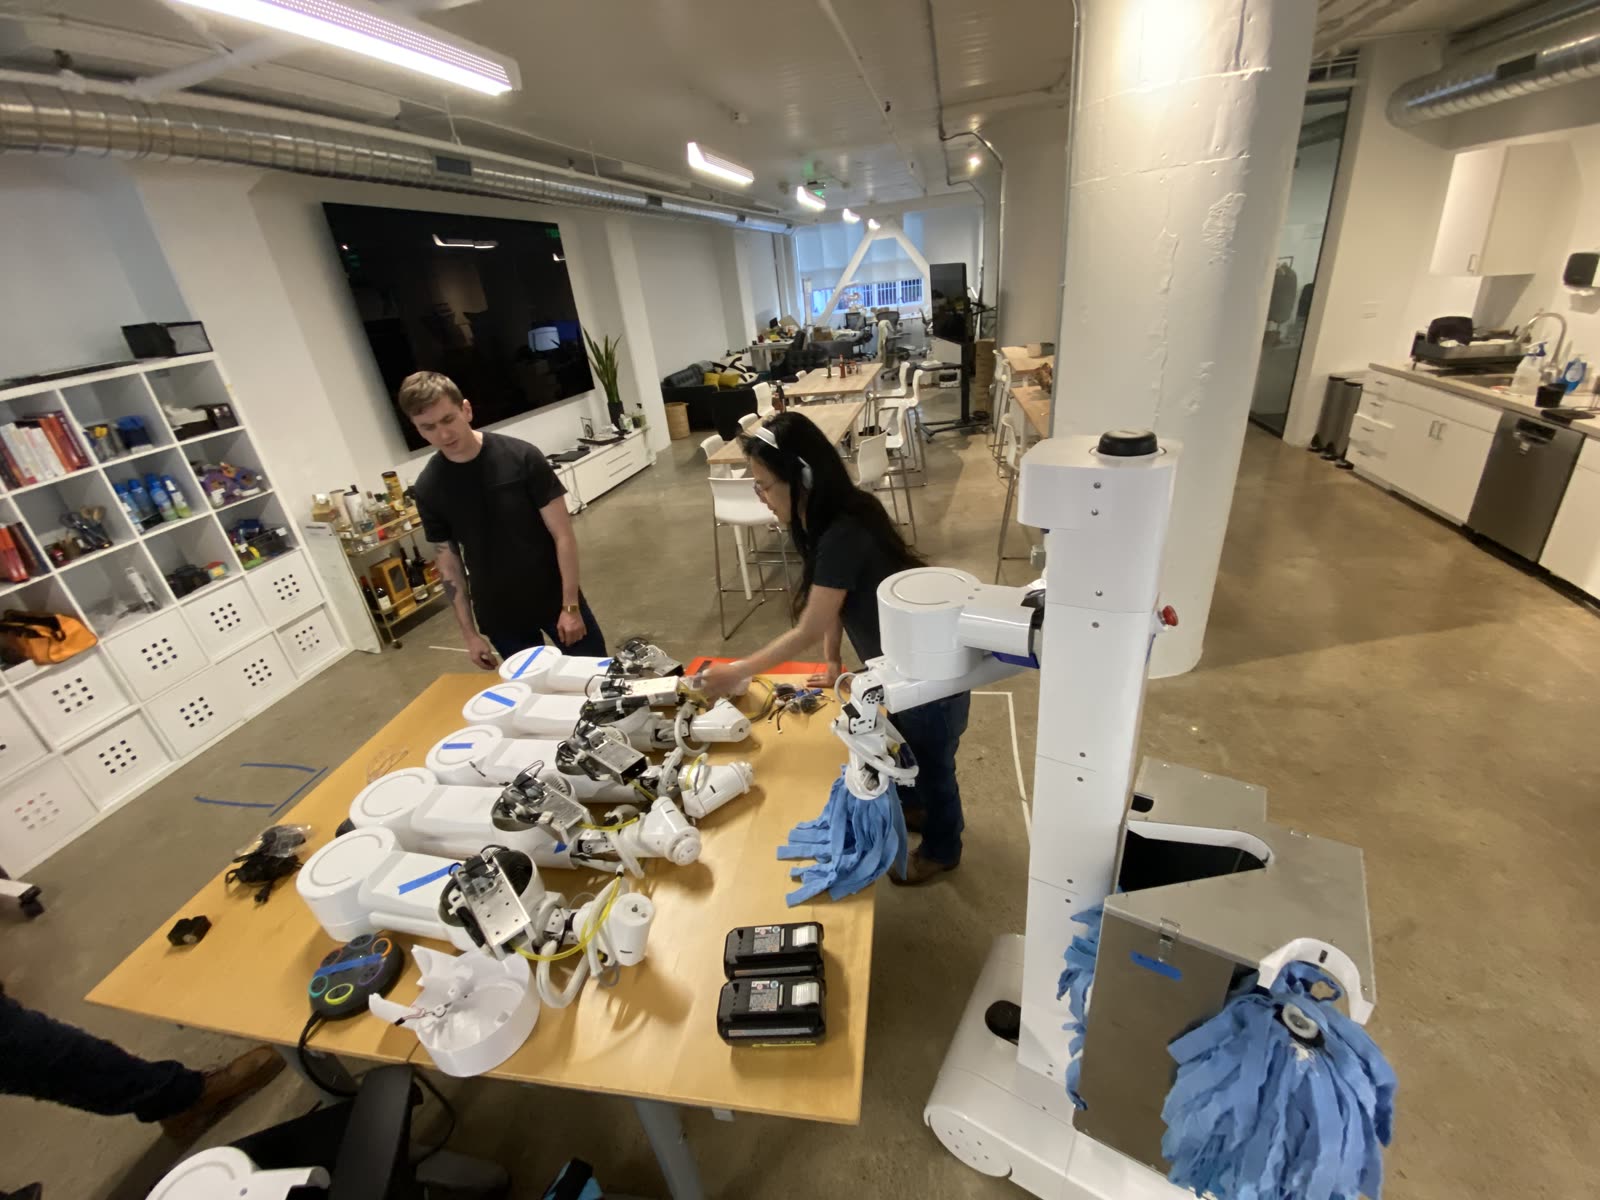
Robotics Engineer at Peanut Robotics
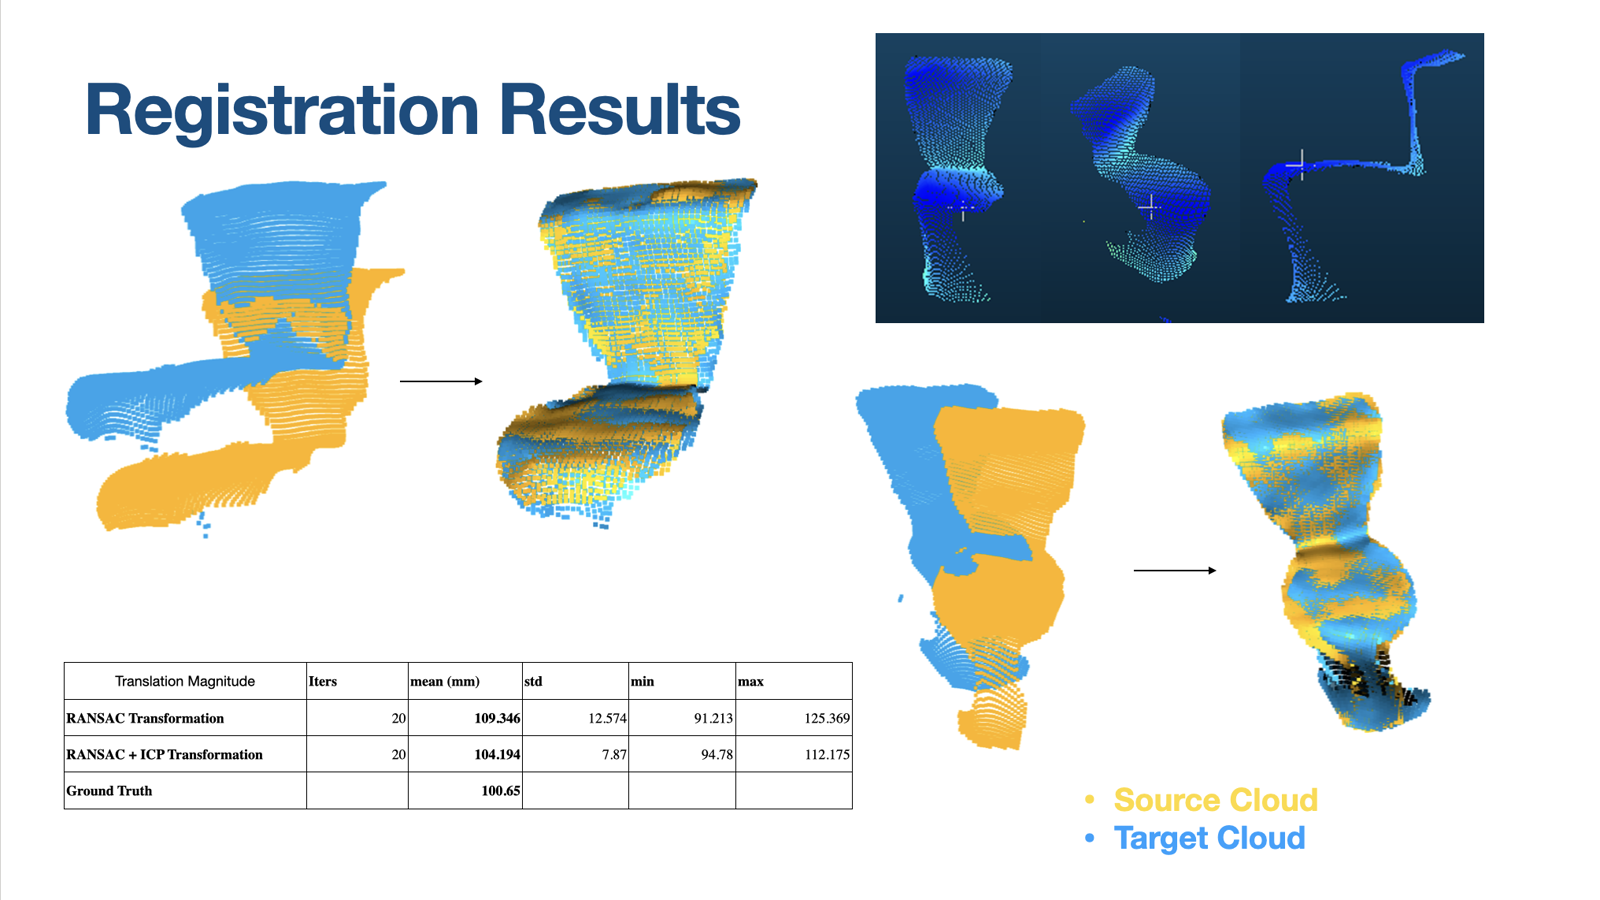
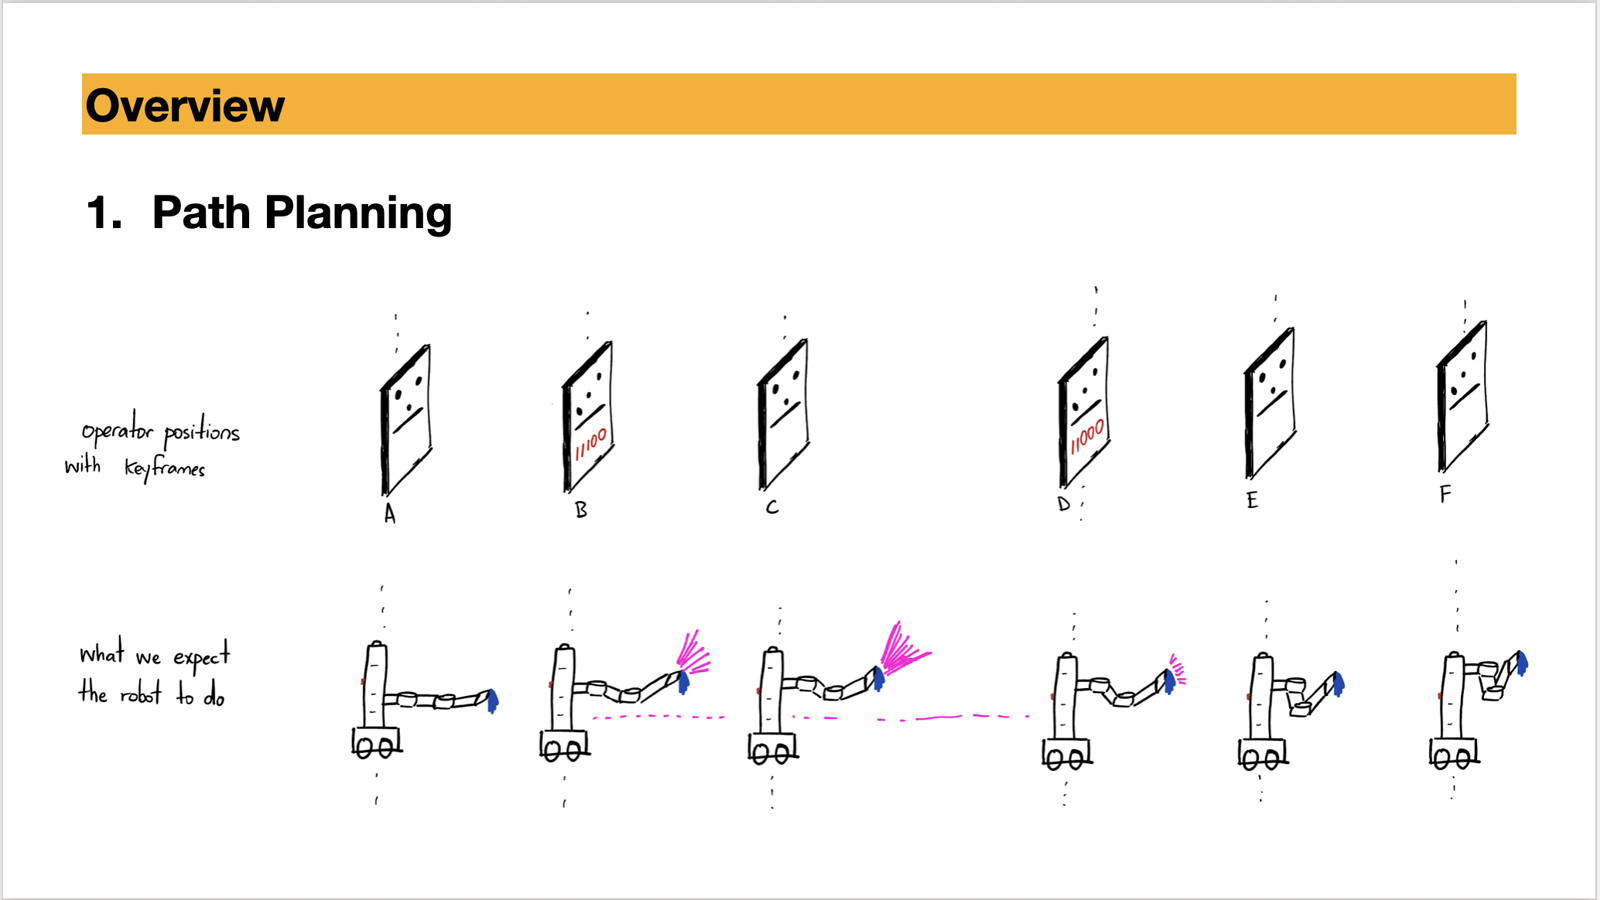
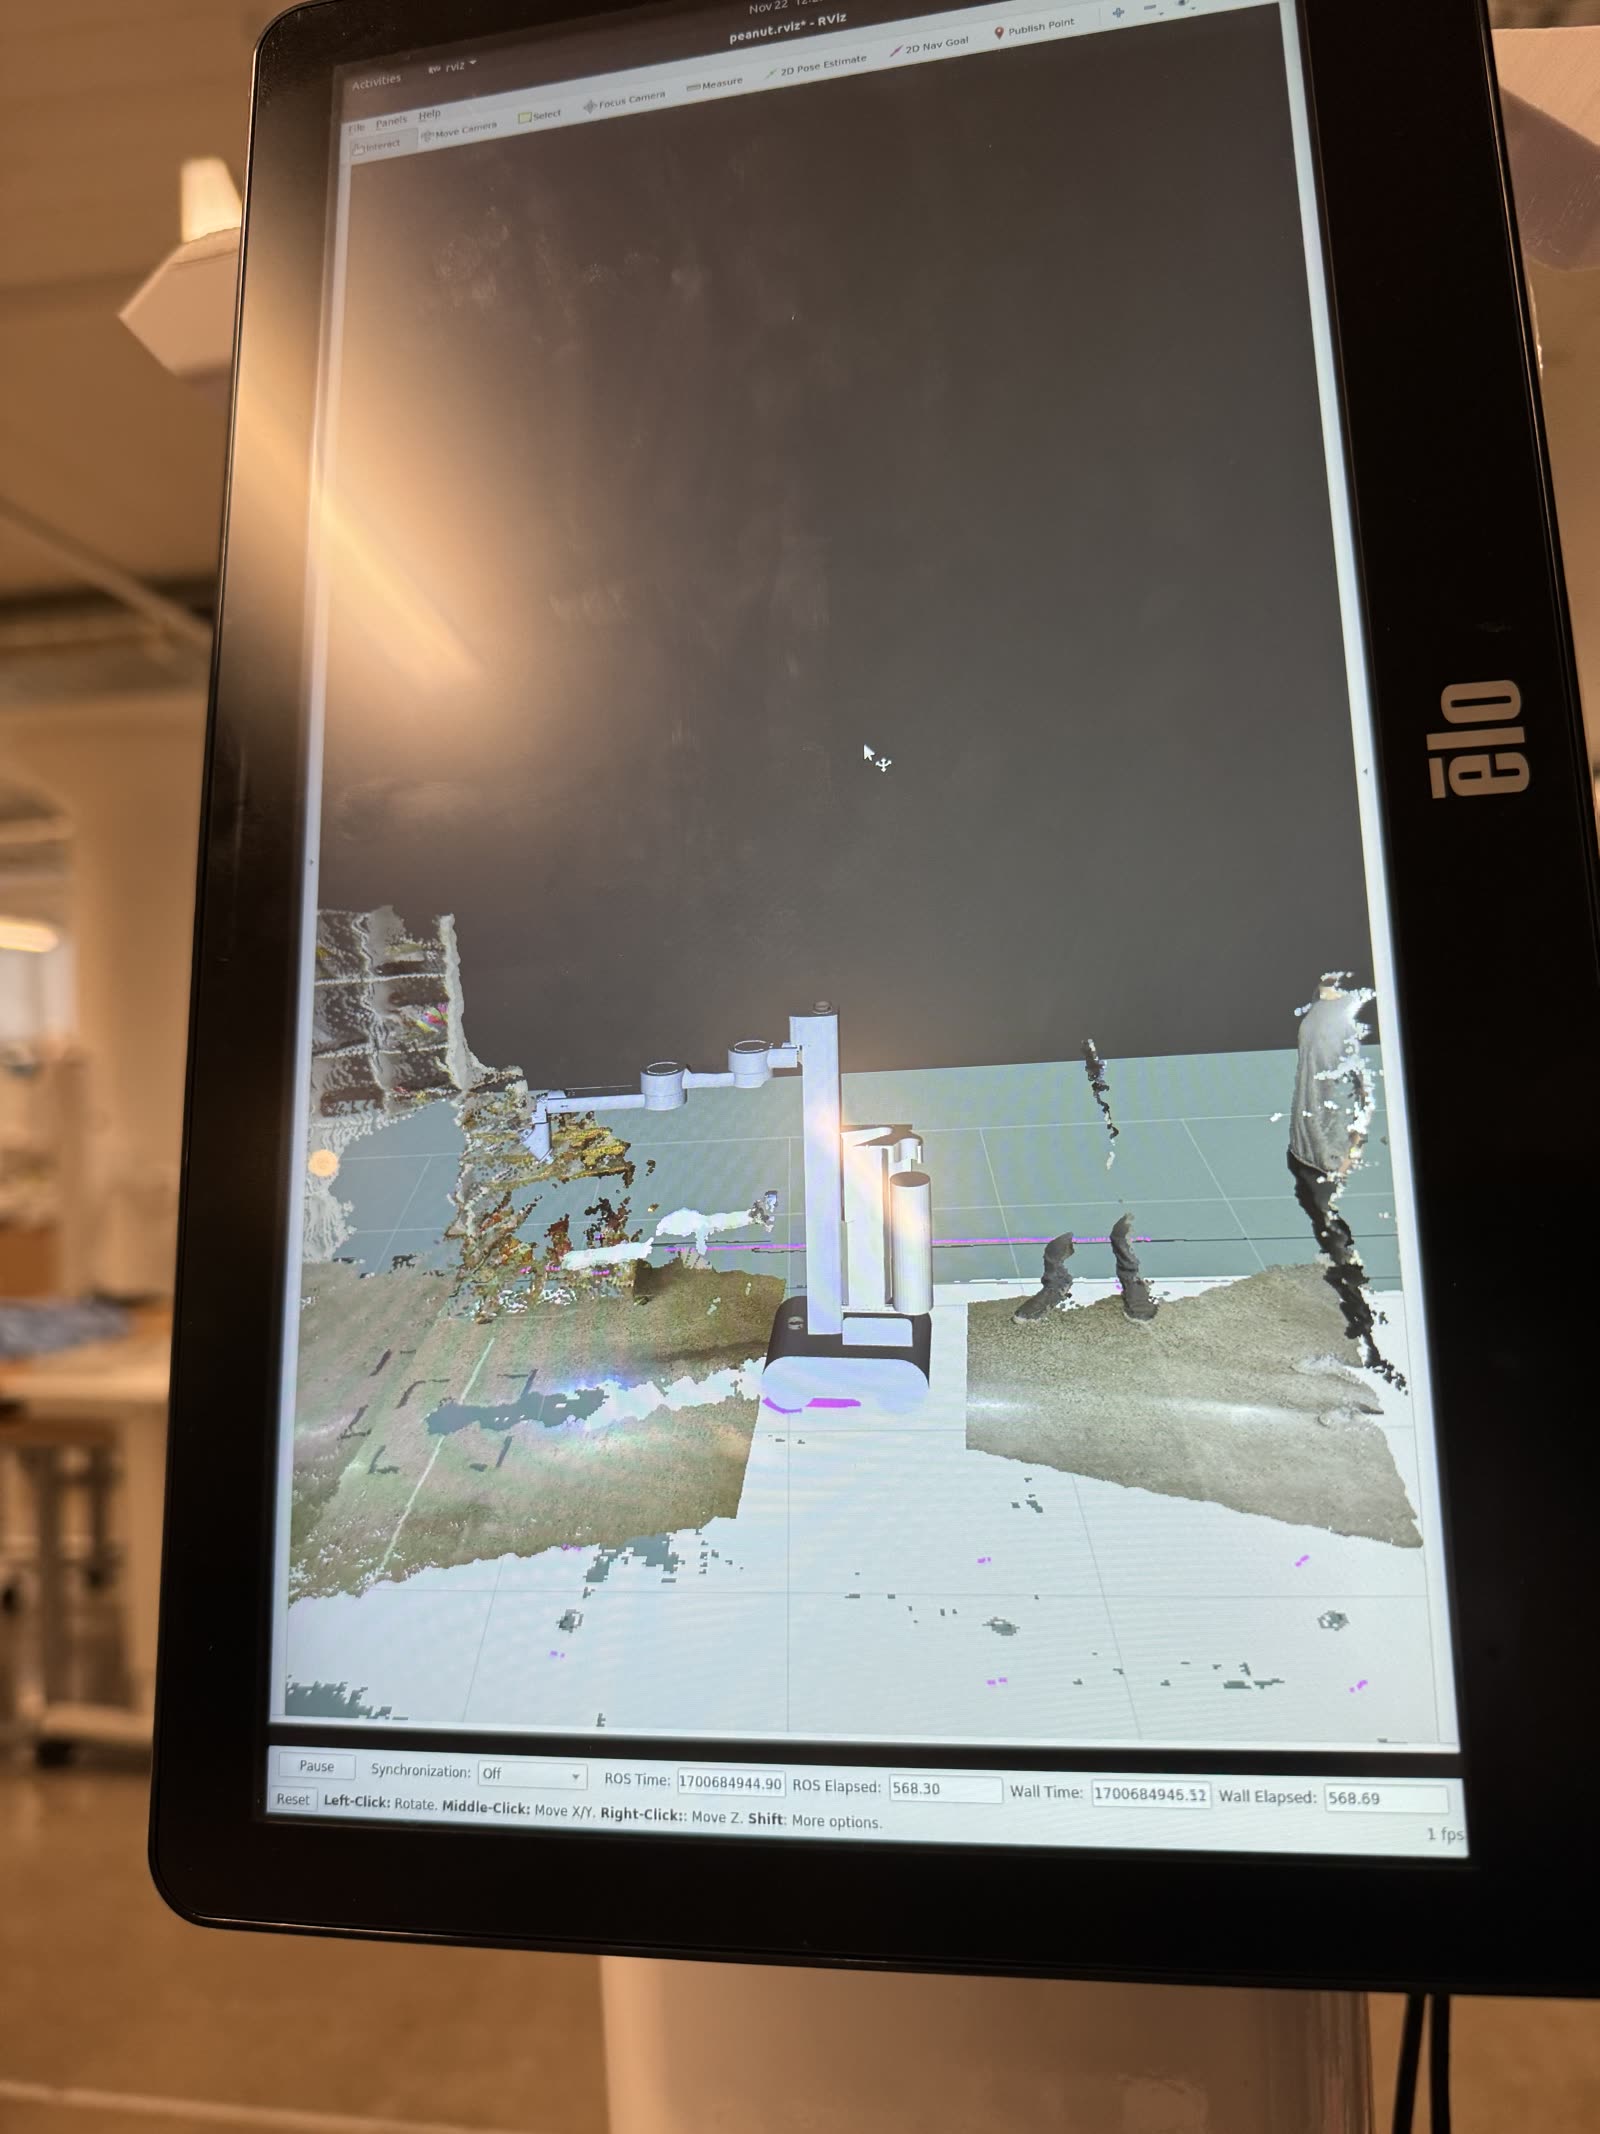
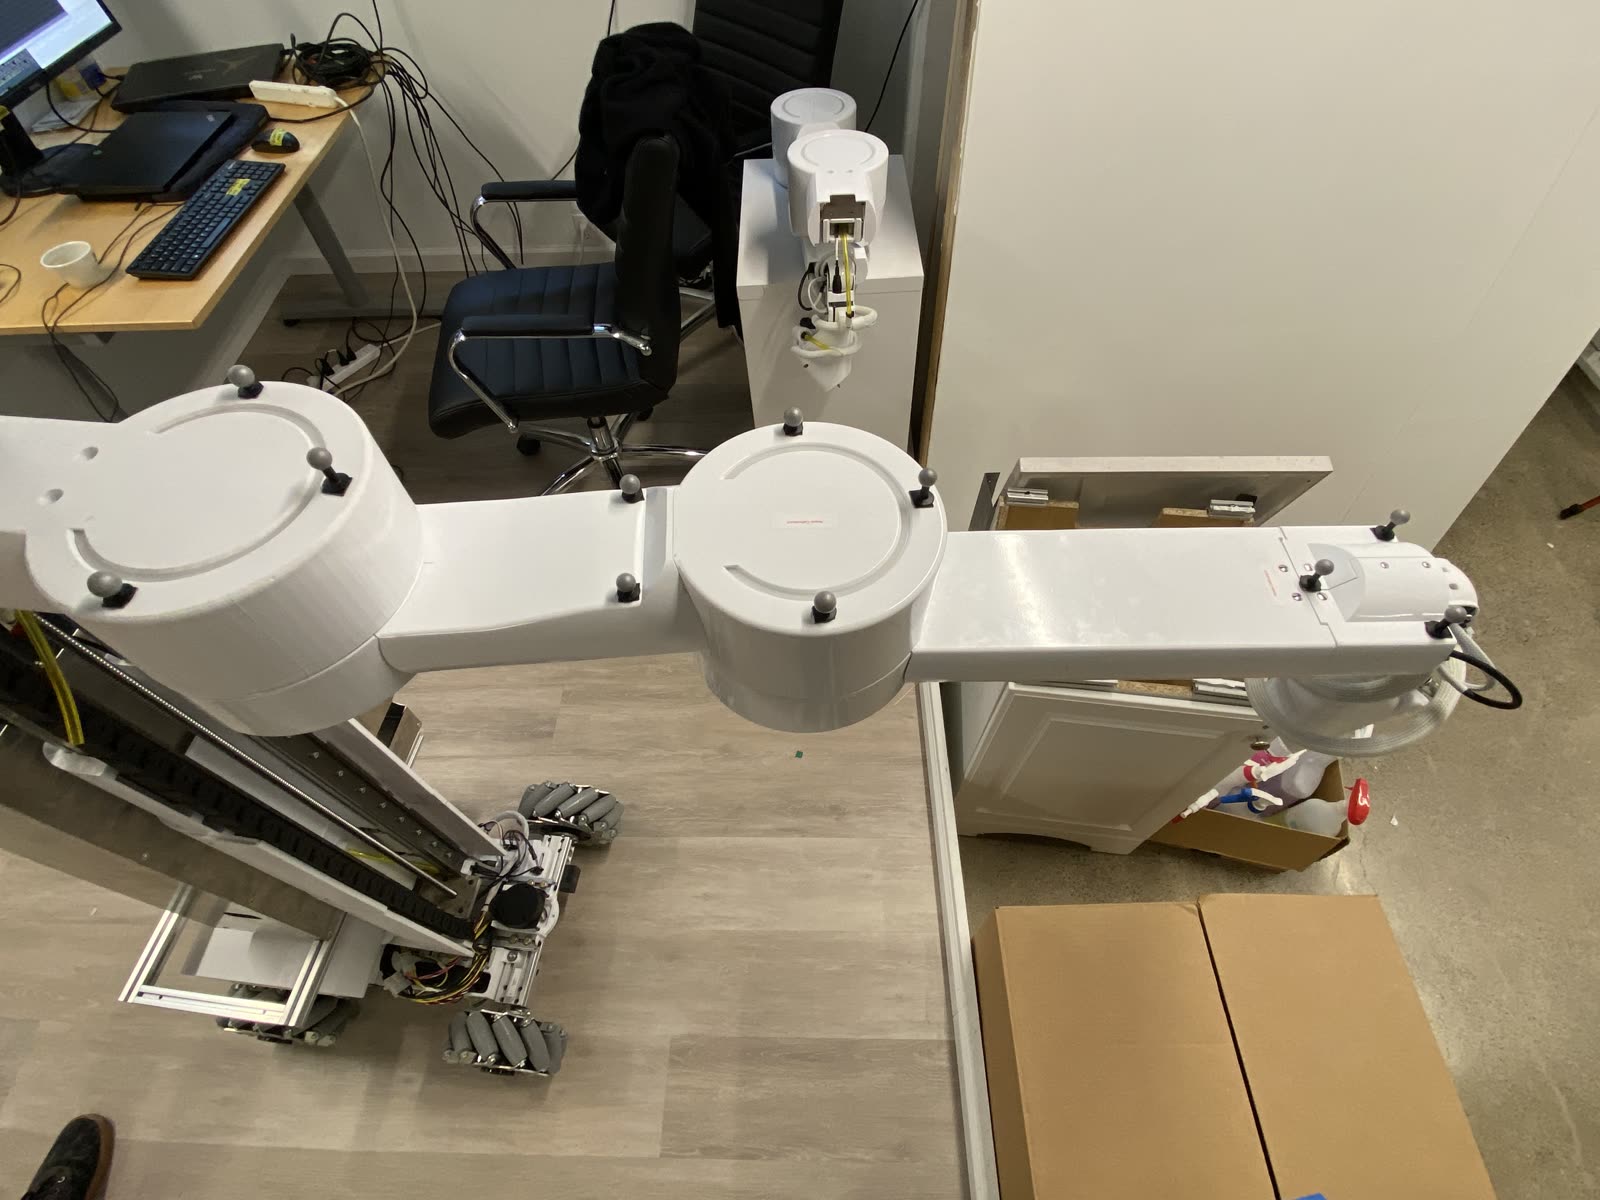
Owned the arm software stack on a mobile manipulator for hotel bathroom cleaning: TOPPRA trajectory generation, ICP+RANSAC vision, depth camera integration, and a live trajectory recording system that cut operator training from hours to minutes.
TOPPRA ros_control ICP / RANSAC C++ OpenCV
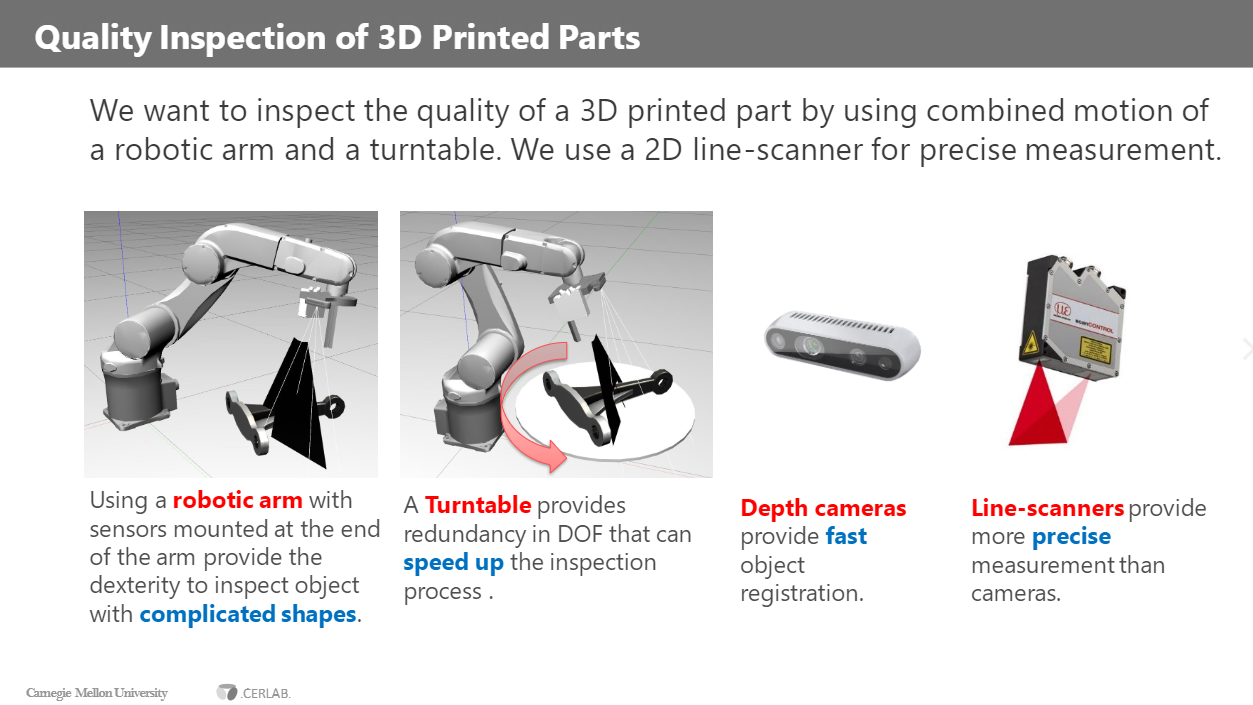
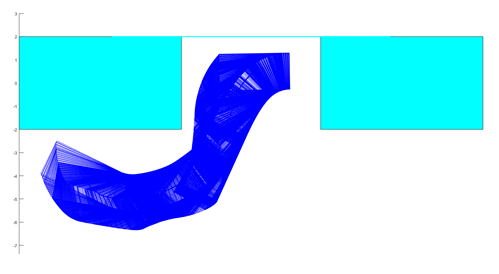
Robotic metrology system for scanning 3D-printed parts
Graduate Research · CMU CERLAB
Robotic post-processing of additive-manufacturing parts
Quality inspection of complex 3D-printed parts: coverage planning for a robot arm and turntable so a line-scanner can fully scan an arbitrary object.
Motion Planning PRM TSP ROS
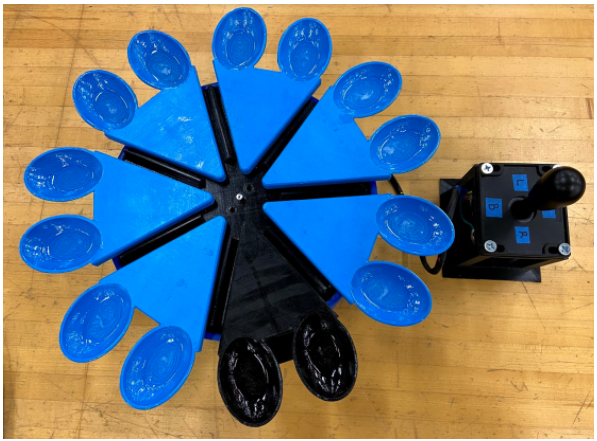
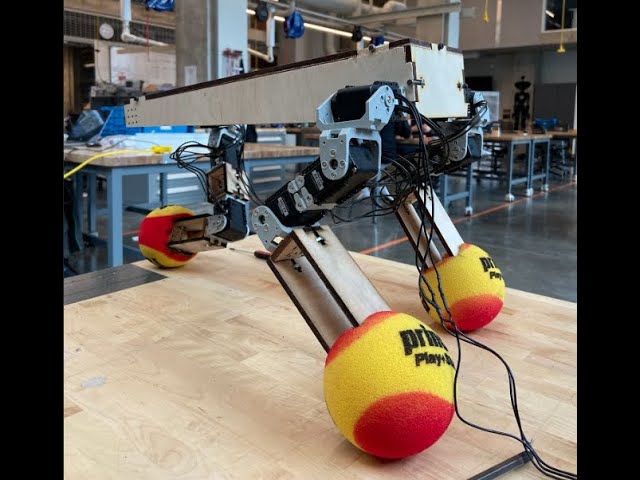
The automated eating apparatus
Senior Capstone · Rose-Hulman · South Korea
Automated eating apparatus, and representing the USA in South Korea
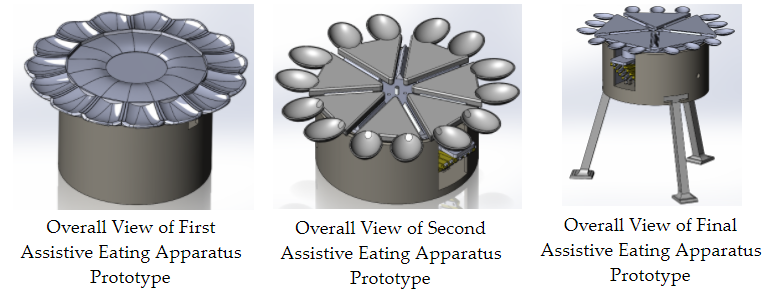
A low-cost robotic feeding device for a quadriplegic client, built over three prototypes at roughly $150 against $5,000 to $10,000 commercial arms. It took us to the E²Festa in South Korea, representing Rose-Hulman and the USA, for a 10th-place finish.
Arduino Mechanical Design Assistive Robotics

Home lab

Ongoing

SO-101 arms on my living-room table, learned policies, and ordinary household jobs. The interesting question is not merely whether a policy works, but what it actually learned when it does. The setup and what I've learned so far →

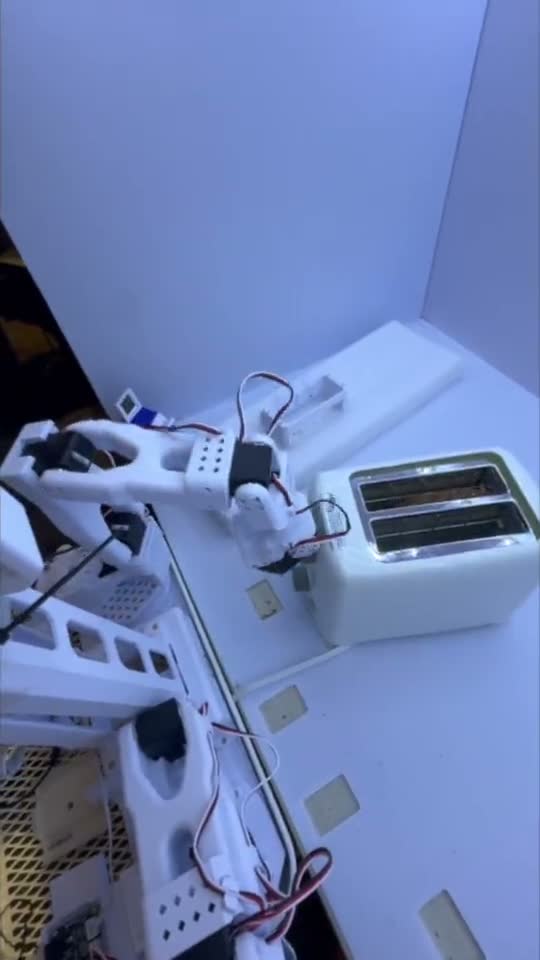
A robot arm placing bread into a toaster
Hackathon · 2 days
Toasting bread
Four people, one weekend: bread into the toaster, press the button, retrieve the toast. Three manipulation problems chained together in a demonstration using ACT and SmolVLA.
ACT SmolVLA Deformable Objects
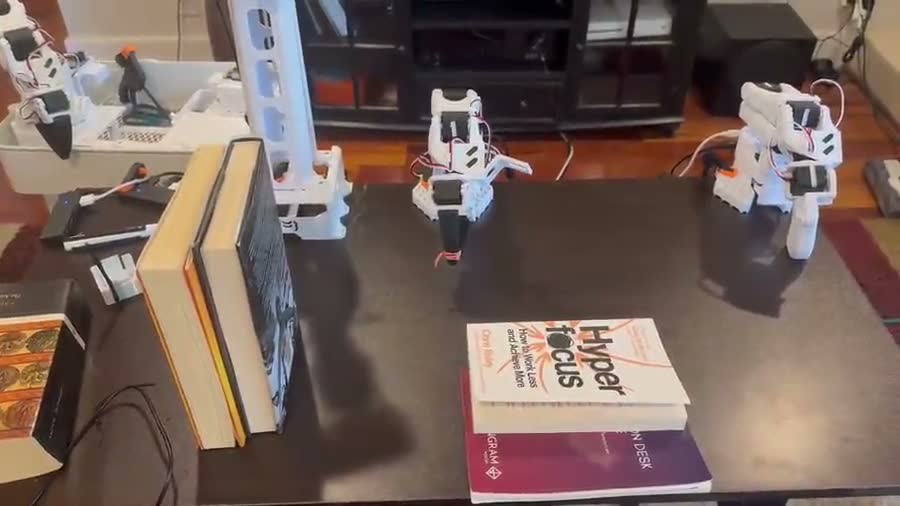
Robot arms picking up and stacking books on a table
Library robot · Ongoing
Picking and stacking books
In the experiments so far, an ACT policy picked up a few unseen books and a book that was partly occluded.
ACT Informal Trials Occlusion
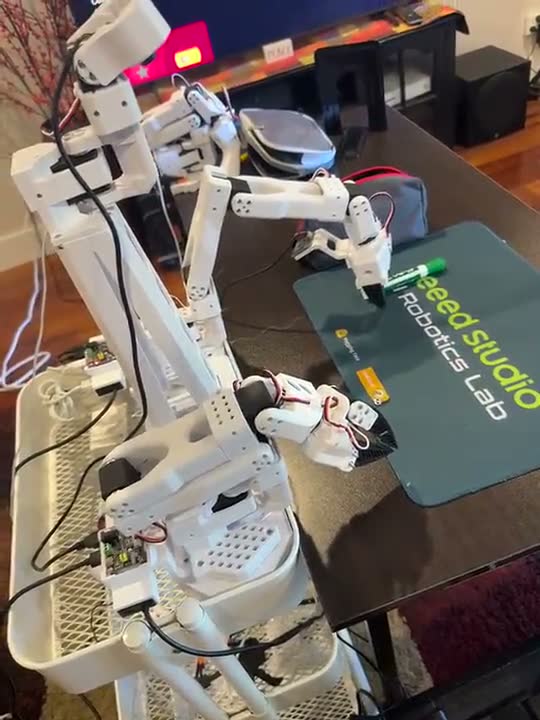
A robot arm picking up a pen from a table
Desk cleanup · Ongoing
The pen task
I tried several policies on a pen-pickup task. Their behavior changed when I varied the pen, its orientation, or the drop target.
MolmoAct Diffusion Policy VLA

Academic

CMU & Rose-Hulman

Coursework and research from grad school at Carnegie Mellon and undergrad at Rose-Hulman: computer vision, SLAM, controls, assistive robotics, and CAD.

Carnegie Mellon University
Graduate · Carnegie Mellon
CMU projects
Robotic post-processing research, lunar rover perception, legged locomotion, and graduate coursework in computer vision and SLAM.
Computer Vision SLAM Motion Planning
Rose-Hulman Institute of Technology
Undergraduate · Rose-Hulman
Rose-Hulman projects
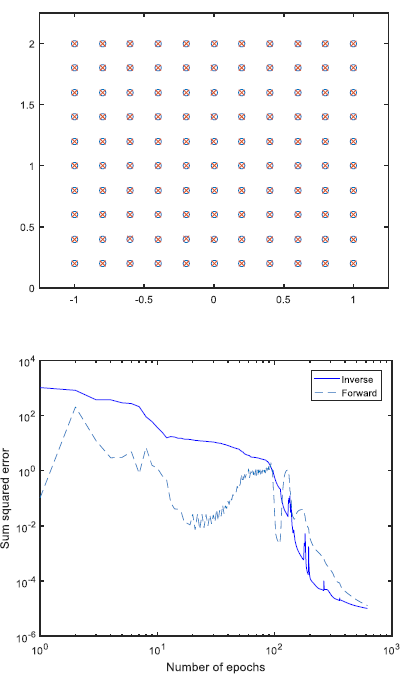
A year-long assistive-robotics capstone that represented the USA in South Korea, plus controls, machine-learning, and CAD coursework.
Assistive Robotics Controls CAD